


A Nonlinear Topology Optimization Framework for Hyperelastic Pneumatic Soft Robots
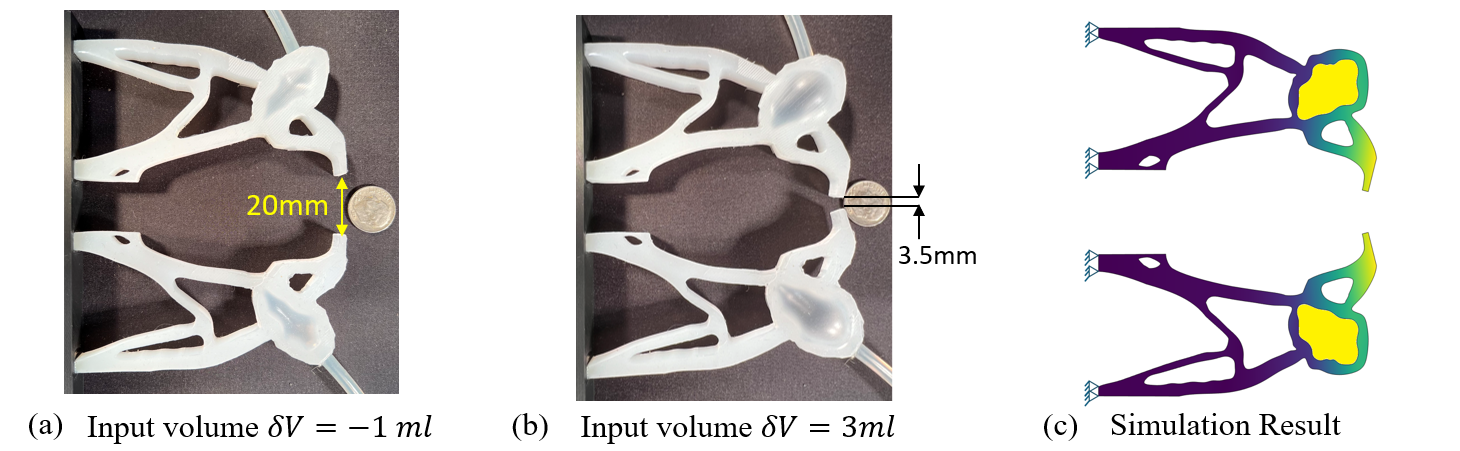
In this work, we propose a unified nonlinear level-set topology optimization framework for the systematic design of hyperelastic soft robots with design-dependent pneumatic actuation. The proposed framework incorporates both geometric and material nonlinearities through a finite-strain formulation with a compressible Neo-Hookean constitutive model, enabling accurate representation of large deformations in soft robotic structures. An adjoint-based shape sensitivity analysis is developed by retaining higher-order displacement-gradient terms to ensure consistency between nonlinear structural mechanics and topology optimization. To incorporate design-dependent pneumatic actuation, a novel boundary-capturing and extraction algorithm is introduced to automatically identify internal pneumatic chambers and apply pressure loads along their evolving boundaries. Unlike conventional approaches with predefined pneumatic chamber geometries, the proposed framework enables simultaneous optimization of structural topology and pneumatic actuator configurations, allowing freeform chamber evolution, topological merging of pneumatic chambers, and dynamic redistribution of chamber volumes throughout the optimization process. Furthermore, a deformation-dependent pressure formulation based on Nanson's relation is developed to account for pressure traction changes under large deformations. The effectiveness of the proposed framework is demonstrated through nonlinear structural benchmarks and pneumatic soft gripper designs with progressively increasing geometric freedom, including fixed, parameterized, freeform, and multi-chamber configurations. Experimental validation using fabricated silicone prototypes further demonstrates the capability of the proposed framework to generate efficient, highly deformable pneumatic soft robotic structures.
Material and Spatial Configurations in Finite Deformation
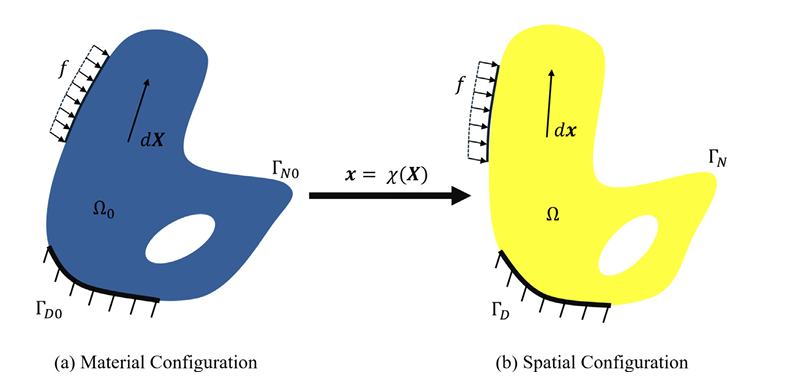
Illustration of the reference and deformed configurations of a hyperelastic structure under finite deformation, showing the deformation mapping and corresponding boundary conditions.
Design-Dependent Pneumatic Boundary Capturing and Extraction
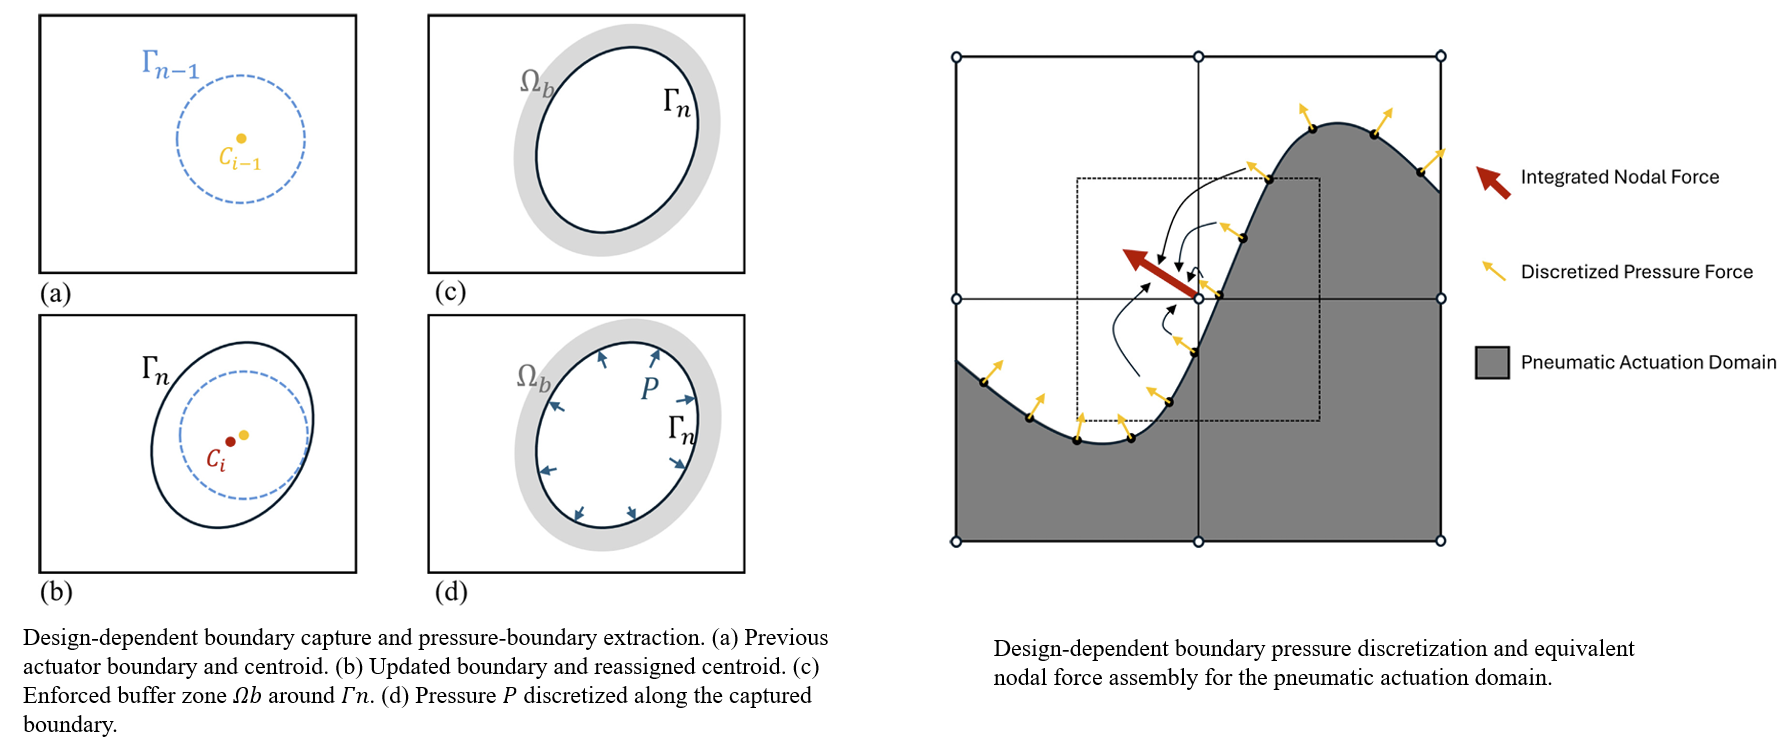
Illustrations of the design-dependent pneumatic boundary capturing and extraction algorithm, pressure load discretization, and equivalent nodal force assembly along evolving actuator boundaries.
Progressive Evolution of Nonlinear Topology Optimization for Hyperelastic Pneumatic Soft Robots
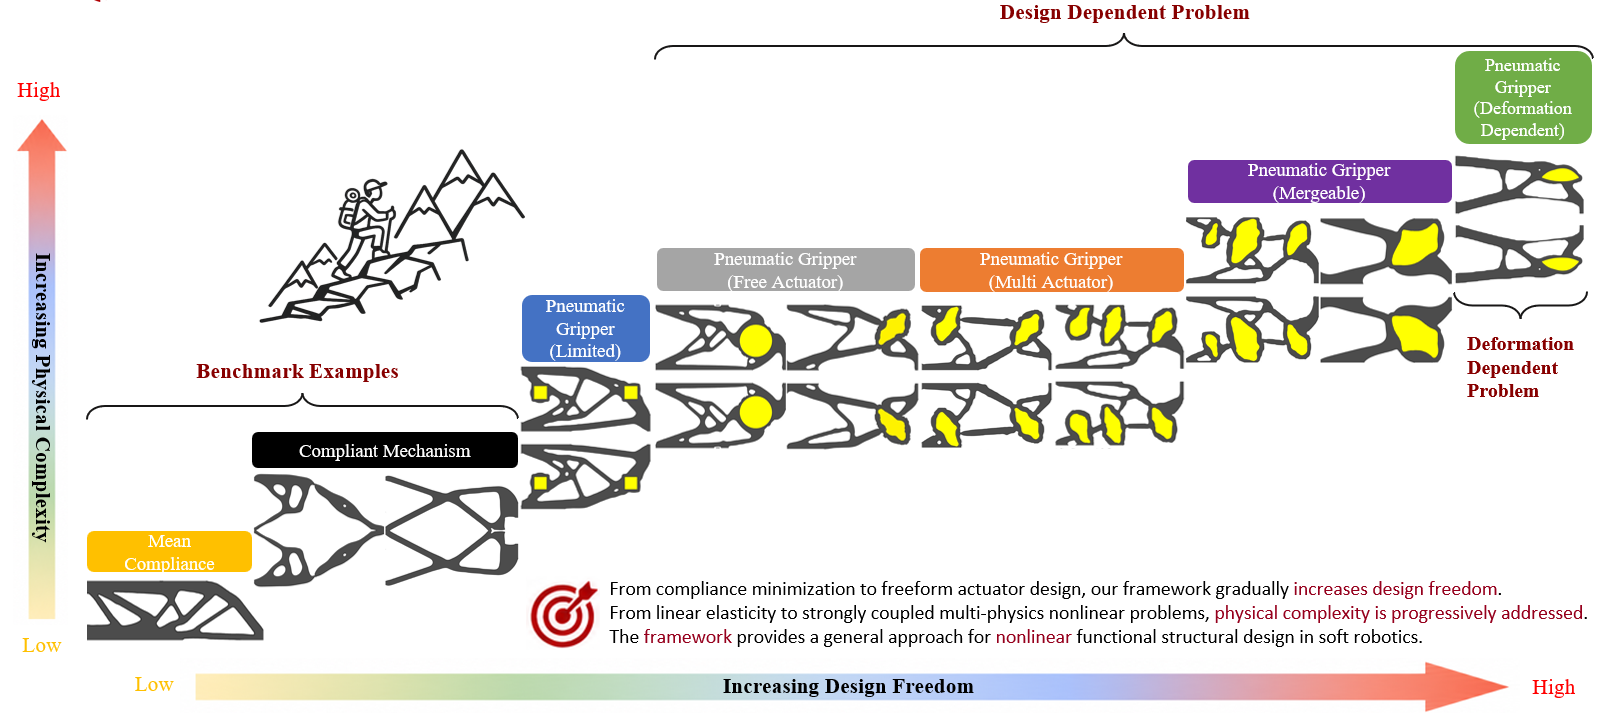
The proposed nonlinear topology optimization framework progressively addresses increasing physical complexity and design freedom, ranging from conventional structural optimization and compliant mechanisms to hyperelastic soft robots with design-dependent pneumatic actuation. By gradually relaxing geometric constraints on pneumatic actuators, the framework enables the transition from fixed and parameterized chambers to freeform, multi-chamber, and mergeable pneumatic configurations. This progression allows simultaneous optimization of structural topology and actuator geometry, including automatic chamber evolution, merging, and volume redistribution. Furthermore, deformation-dependent pressure loading is incorporated to account for the nonlinear interaction between pneumatic actuation and large structural deformations, demonstrating the framework's versatility in designing complex soft robotic systems.
Experiment Varification
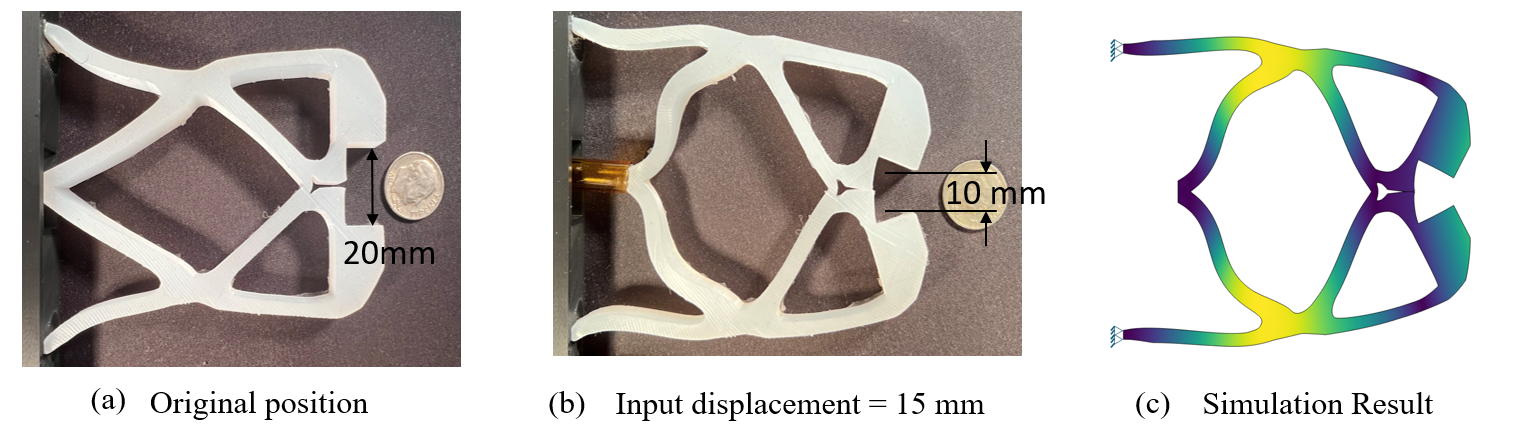
Representative publications:
|
Journal: 1. Zhuang, R., Sadasivan, C., Gu, X. D., & Chen, S. "Nonlinear level-set topology optimization of hyperelastic soft robots with design-dependent pneumatic actuation." Computer Methods in Applied Mechanics and Engineering 461 (2026): 119205. |
Conference:
- Ran Zhuang, Chander Sadasivan, Xianfeng David Gu, Shikui Chen*, “LEVEL-SET NONLINEAR TOPOLOGY OPTIMIZATION FOR LARGE-DEFORMATION COMPLIANT MECHANISMS WITH HYPERELASTIC MATERIALS”. the ASME 2025 International Design Engineering Technical Conferences & Computers and Information in Engineering Conference (IDETC/CIE 2025), August 17-20, 2025, Anaheim, CA, USA.